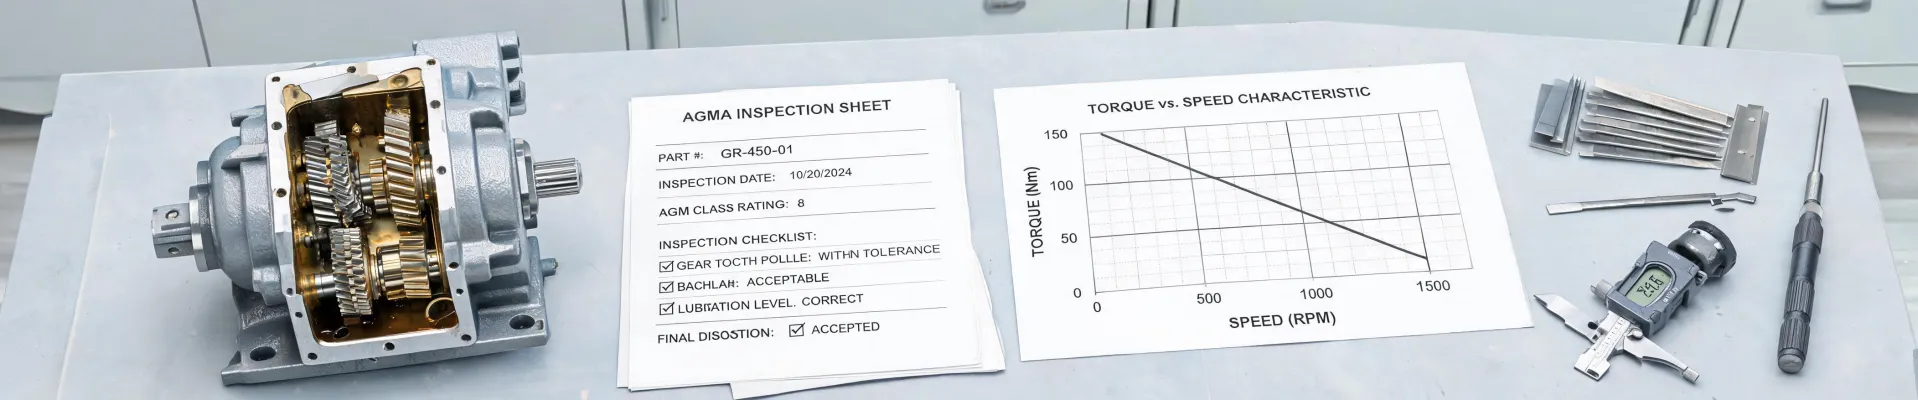
I've handled Boston Gear product and motor orders for about eleven years. In that time, I've personally made—and documented—fourteen significant specification mistakes. Figure roughly $38,600 in wasted budget. I now maintain the checklist our team uses before every order, because I don't want anyone else repeating those calls.
The most expensive lesson I learned? The component that breaks isn't always the one that failed.
The Phone Call That Started It
September 2022. A customer calls, and he isn't happy. "Your gear reducers are junk," he says. "We've replaced two in six months on the same conveyor line."
I started to get defensive. Then I asked what was driving the reducers.
"A three-phase squirrel cage induction motor," he said. "We run it through a VFD."
"Okay," I replied. "What's a VFD got to do with it?"
He asked the question with frustration in his voice. But it was the right question. The answer, as it turns out, is everything.
"What's a VFD?" (Yes, That's a Legit Question)
I get asked that more often than you'd think. VFD stands for variable frequency drive. It's an electronic controller that sits between the plant's AC power supply and an AC induction motor.
A VFD doesn't just reduce voltage like a dimmer. It adjusts both frequency and voltage together, which lets the motor run at different speeds while maintaining usable torque. That's a powerful capability. It gives you soft starts, adjustable speed, and controlled acceleration without mechanical changes.
But here's the thing: the VFD changes the behavior of the motor sitting upstream of the gearbox. And most gear reducer ratings assume a fixed-speed motor running across the line at its nameplate rating. Once you add a VFD, that assumption goes out the window.
Why the Reducer Really Fails
It's tempting to think a gearbox is just a torque multiplier. Put torque in, multiply by the ratio, get torque out. If it were only that simple, selection would be arithmetic and field failures would be rare.
A gearbox rating is a promise—but only under specific input conditions. The mismatches I see most often fall into three categories.
1. The Motor Is No Longer "Standard"
The most common setup is also the easiest to misunderstand: a standard squirrel cage induction motor, a speed reducer, and a VFD added later for process flexibility.
Here's the hidden problem. A typical fan-cooled AC motor has a cooling fan mounted on the motor shaft. At full speed, that fan moves plenty of air. But when the VFD slows the motor down—say, to 30 or 40 Hz under a continuous load—the fan slows down too. The motor can still be drawing significant current, but it's not cooling itself the way it was designed to.
That's why inverter-duty motors exist. NEMA MG 1 Part 31 addresses the insulation and thermal requirements for motors used with adjustable speed drives. Sometimes an external blower is needed. It's not optional in every application—but plenty of people treat it that way.
I learned this in 2019, when I processed a replacement reducer for a conveyor that kept stopping. The customer thought the reducer was seizing. We swapped it. The same complaint came back within weeks. Turned out the motor was overheating and tripping on a VFD at low speed. The reducer wasn't the problem. I spent roughly $900 on a part the application didn't need, plus the embarrassment of explaining it.
Worse than the cost? The customer's downtime. That's the part no catalog number captures.
2. The Peak Torque Problem with Servo Motors
The second scenario shows up in newer machines: a servo motor doing indexing, stacking, or high-speed positioning. Let's say a Kollmorgen servo motor, which is a solid piece of equipment. Servo motors can produce a lot of punch in a small frame.
Here's the catch. A servo motor's peak torque can be two to three times its continuous torque during acceleration, deceleration, and direction reversals. If you size the gear reducer based only on RMS torque—the average torque over the duty cycle—you're missing what the gear teeth actually experience.
The gearbox sees those peaks. Repeatedly. The first symptom is usually noise or backlash. Then the teeth fail. And the reducer gets blamed, even though the real mistake was ignoring the peak torque in the specification.
I have mixed feelings about that failure mode because it's so avoidable. The motor manufacturer didn't cause it. The reducer didn't cause it. The spec did.
For servo applications, always check the reducer's peak torque rating and torsional stiffness. RMS torque is a starting point, not a finish line. That's why reducer data sheets include service factors and application notes.
3. The Input Speed Limit You Didn't See
The third cause is less dramatic but just as real: VFDs let induction motors run faster than their rated speed. A motor rated at 1,750 rpm at 60 Hz might be pushed to 90 Hz or even 120 Hz to gain throughput.
Gear reducers have maximum input speed ratings. Run a reducer above that limit and you get oil churning, seal problems, bearing heat, and premature wear. The torque may be fine. The speed is not.
When people search for "boston gear boxes," they usually find torque tables and ratio charts. Those matter. But maximum input speed matters just as much—especially when a VFD is involved. It's one more reason a model number alone isn't enough to make a good decision.
What These Mistakes Actually Cost
A $3,200 order in 2021 comes to mind. The gearboxes and a Kollmorgen servo motor looked right on paper. The motion profile was clear. But the reduction was selected on RMS torque, not peak torque. Within months, the customer had noise, then backlash, then downtime. We replaced the units at our cost, but the customer's lost production was far bigger than the invoice.
That's the part that kept me up at night. A warranty replacement covers parts. It doesn't cover a stopped production line.
After the third replacement order in Q1 2024, I created our pre-order checklist. Since then, we've caught 47 potential mismatches before they became failures.
What I Do Now
Before I quote any gearbox or motor order, I ask the questions I should have asked years ago:
- What's the input? A fixed-speed AC motor, a squirrel cage induction motor on a VFD, or a servo motor?
- If there's a VFD, what's the speed range? How long does the system run at each speed?
- What does the torque profile look like—including peak torque and cycle time, not just average load?
- What are the reducer's maximum input speed and thermal limits in this application?
- Is the motor rated for inverter duty, or does the application need external cooling?
When the answer is unclear, I call applications engineering. I don't guess. The boston-gear.com site has product resources and I use them. Sometimes the right answer isn't a bigger reducer—it's a different motor, a different drive, or an inverter-duty motor with forced cooling.
You've probably seen Boston Gear's old tagline: get your rear in gear, Boston. I like it. It's memorable and it fits the industry. But after eleven years and roughly $38,600 of my own mistakes, I read it a little differently now.
Before you get your rear in gear, get the whole drivetrain in gear first. If you keep replacing reducers, stop looking at the reducer. Look at what's happening at the input shaft. That question alone would have saved me a lot of money—and a lot of embarrassment.
Elena Markovic
Elena Markovic is an independent industrial motor and drive systems analyst covering induction motors, servo motors, stepper motors, and variable-frequency drives. She examines IEC 60034-30-1 efficiency classes, IEC 61800-9-2 drive-system losses, speed-torque curves, duty cycles, thermal limits, and feedback compatibility across operating envelopes. Her evidence-led guides help OEM engineers and plant teams select efficient motion packages, plan integration, and reduce commissioning risk.